The BXI-85 is the high-torque flagship of the BXI joint actuator family. It is the joint that lets Ludu 3 squat, jump and climb — and it is available as a standalone module for your own robot.
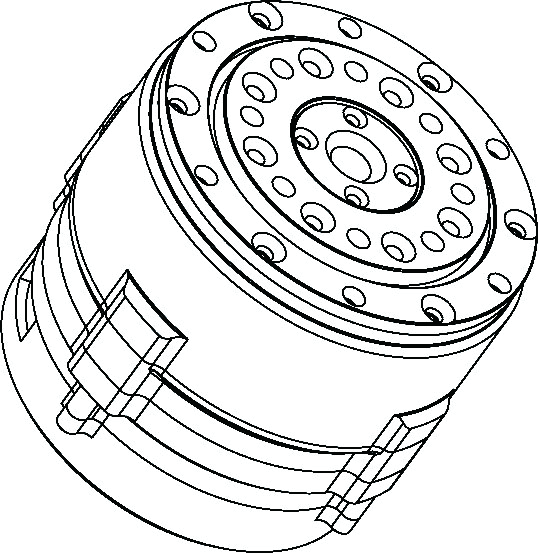
Specifications
| Item | Specification |
|---|---|
| Rated torque | 40 N·m |
| Peak torque | 150 N·m |
| Peak current | 90 A |
| Outer diameter | 99 mm |
| Height | 71.5 mm |
| Hollow shaft | 10 mm |
| Weight | 1.4 kg |
| Supply voltage | 24–48 V |
| Communication | CAN / CAN FD |
| Control | MIT protocol; torque / position / velocity hybrid |
Built for high-load joints
BXI-85 is designed for the most demanding positions on a humanoid or legged robot: thigh and knee joints, the waist, and heavy-payload arm shoulders. In Ludu 3 it serves as the knee actuator, where 150 N·m of peak torque supports dynamic squatting, jumping and cushioned landings.
Hollow wiring and dual encoders
A 10 mm hollow shaft routes power and signal cables through the joint center — no external cable loops to snag, and a clean silhouette for consumer-facing designs. Inside, dual encoders (magnetic + inductive) and a cross-roller bearing deliver accurate, compliant torque control under the MIT protocol.
One family, one protocol
BXI-85 shares its CAN FD MIT-protocol interface with BXI-70 and BXI-50, so a complete robot can mix all three sizes on the same bus. Our roadmap adds five new BXI models in Q4 2026, extending peak torque up to 320 N·m.
Ready to build a humanoid robot under your own brand?
Get a Quote